Apr 2026 – Present
Casualty Detection Model Training & Label Review Platform — AirLab, CMU
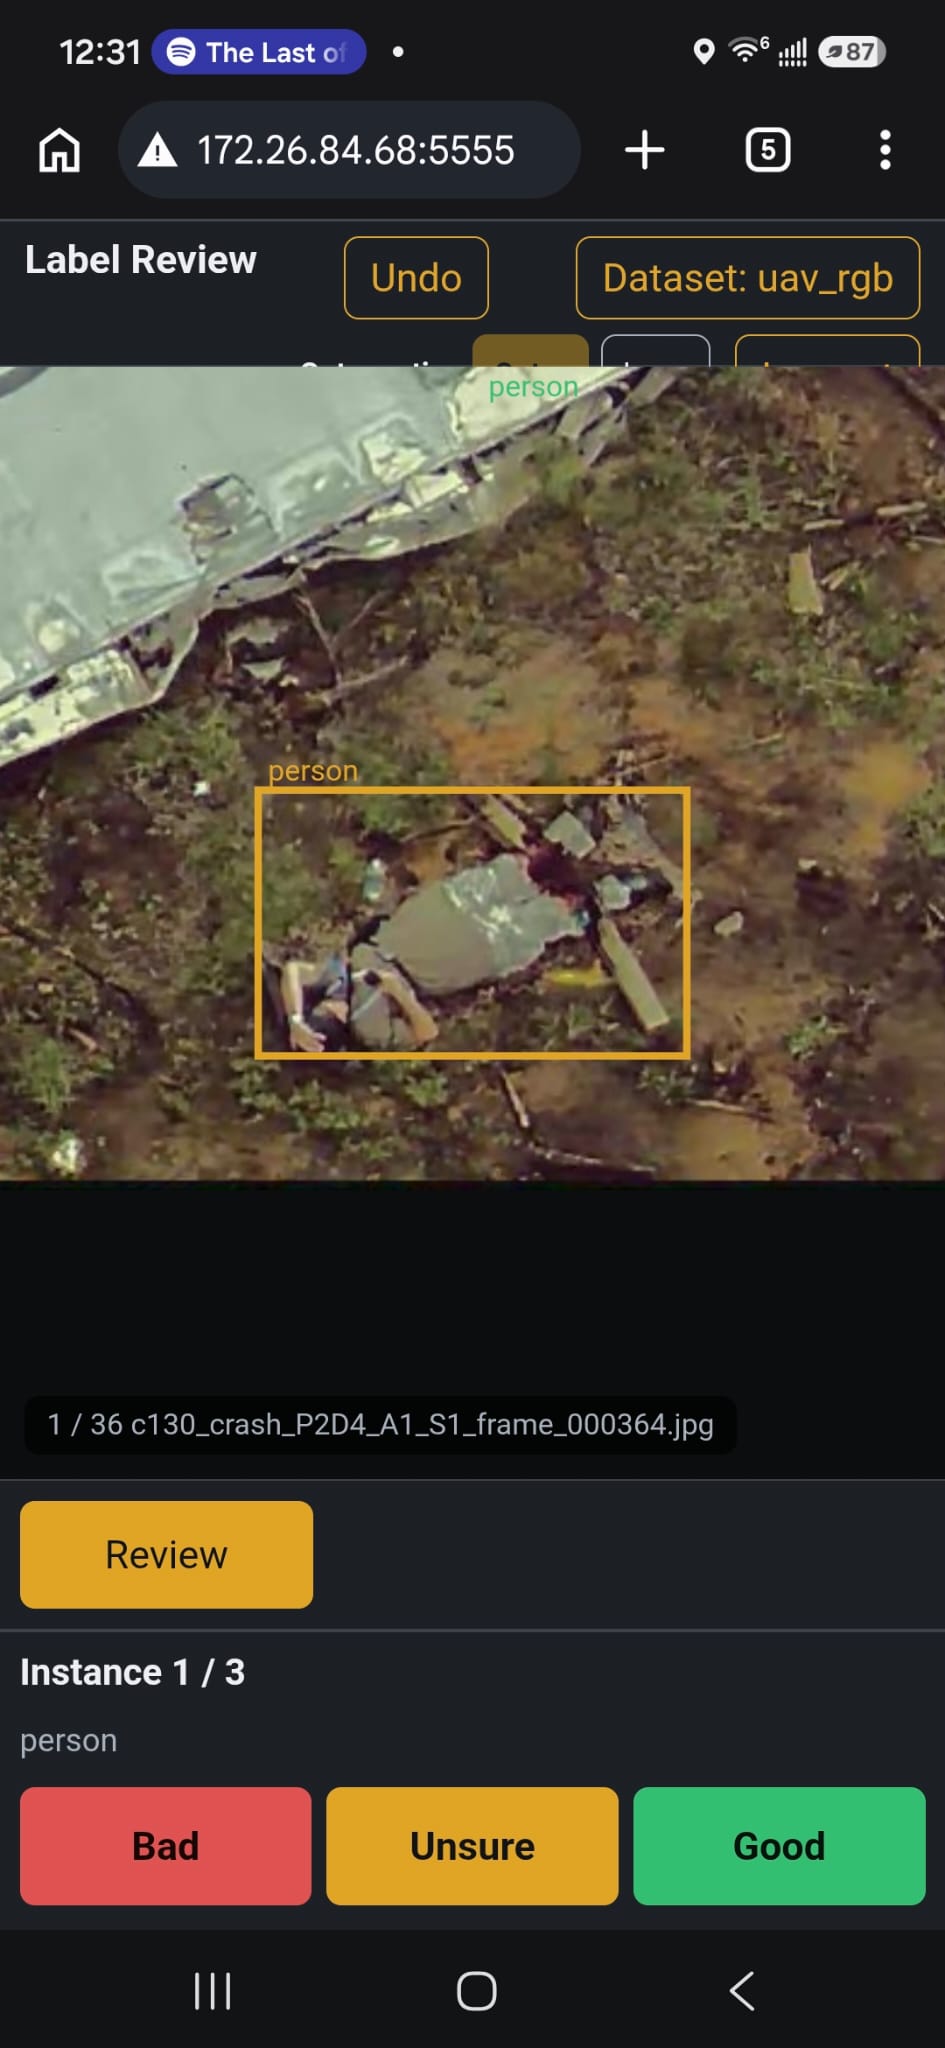
Reproducible training and evaluation pipelines for YOLO and RF-DETR casualty-detection models,
built for the DARPA Triage Challenge at AirLab, CMU. Fine-tuned RF-DETR on historical
field data, achieving F1 +0.0919 and AP50 +0.1432 over the baseline. Also designed and deployed
a self-hosted, multi-user web app for reviewing SAM3-generated labels — supporting rapid first-pass
triage, expert correction, verification, and YOLO-format export.
Oct 2025 – Jun 2026
Casualty 3D Localization Stack — AirLab, CMU
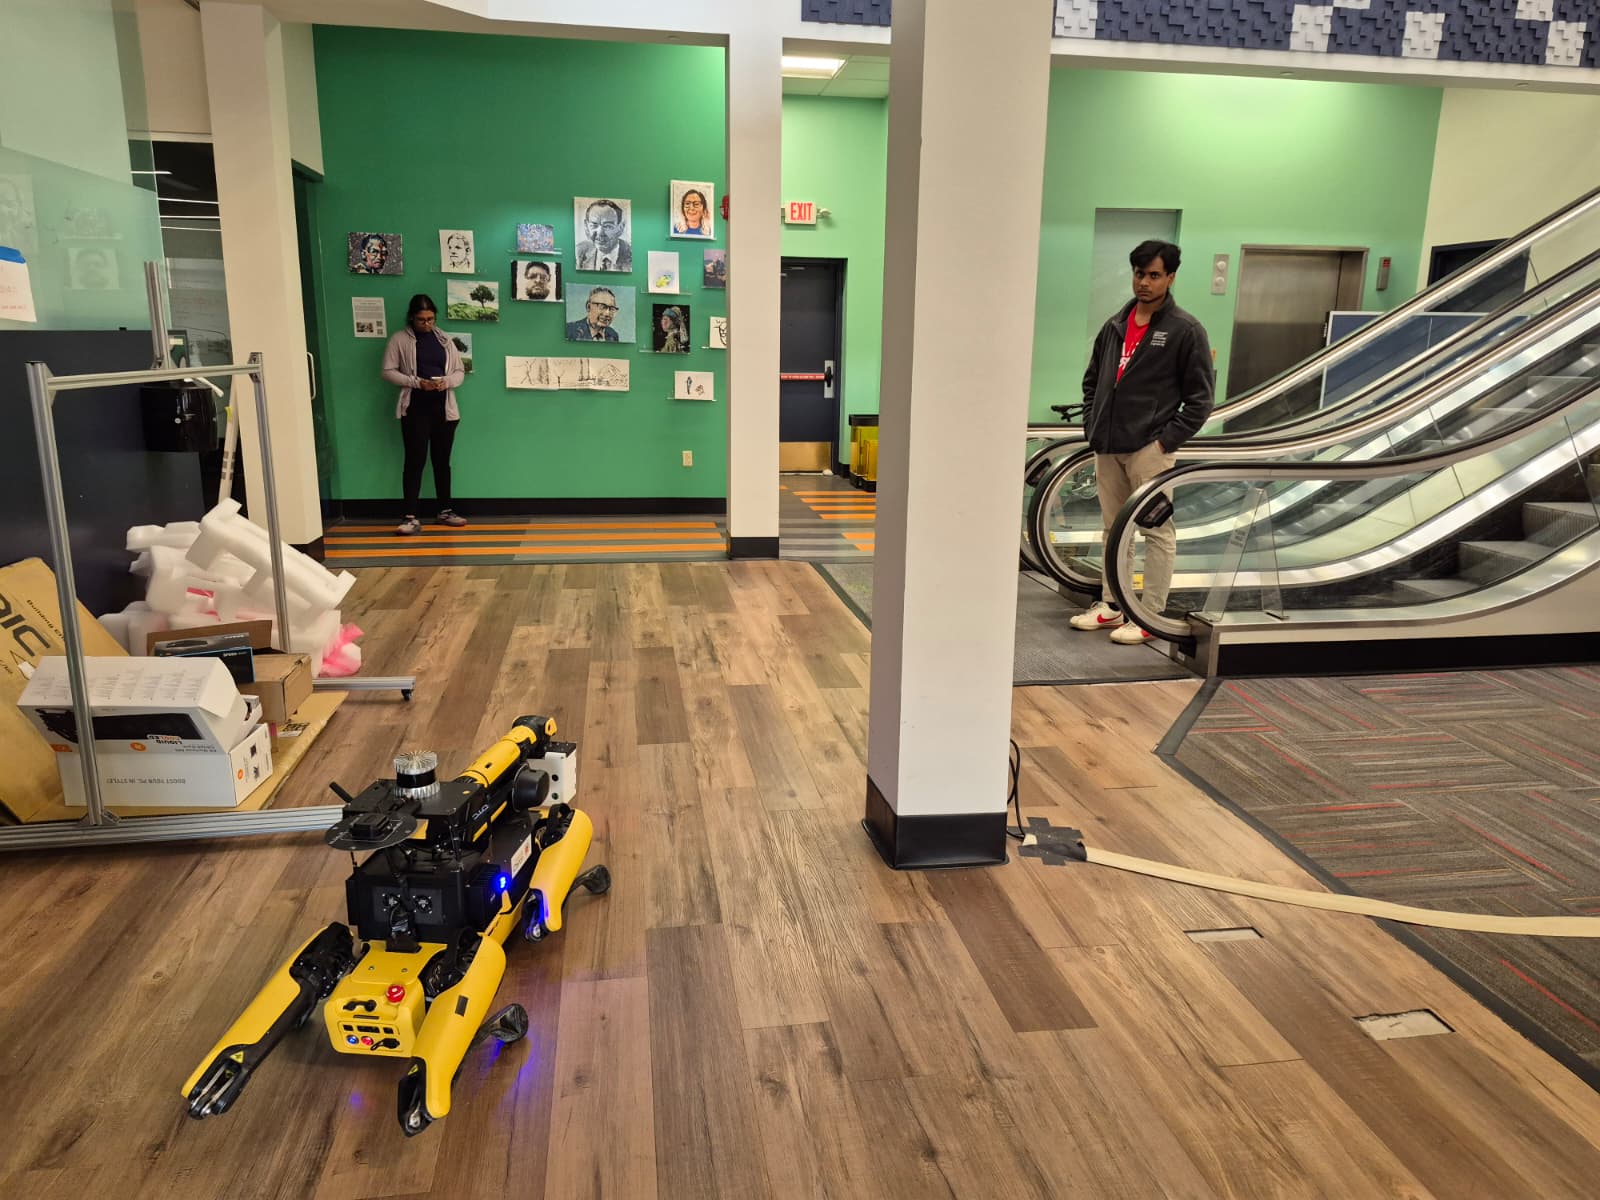
ROS 2 perception pipeline on a Boston Dynamics Spot robot for real-time 3D casualty
localization, built for the DARPA Triage Challenge with Team Chiron at AirLab, CMU.
Detects casualties using a fine-tuned RF-DETR model across six RGB camera streams, then
projects 2D bounding boxes into the LiDAR point cloud for clustering, filtering, and 3D
ground contact estimation. Tracked positions are maintained in the SLAM/odometry frame
and deployed on-robot via Dockerized launch with live Foxglove visualization.
Learning-CAD through projects

Coming from an electronics and software background, mechanical design has always been
a missing piece in my robotics endeavours. Click "Learn More"
to explore the progress I've made so far.